
Pixobots
Last updated on
Pixobots is a Grasshopper plugin for robot programming and digital fabrication. It reads standard URDF files, so any robot described that way could come into the Rhino/grasshopper environment — one toolkit instead of a plugin per brand, and no proprietary formats.
What it does
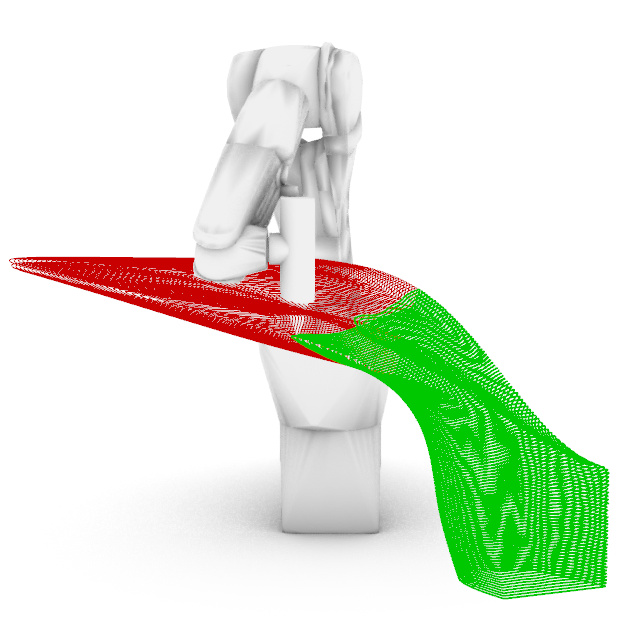
- Kinematics — load any URDF, pose it, solve inverse kinematics, and map the reachable workspace.
- Slicing — flat or non-planar layers along a curved surface, boundary curves for tapered and tubular forms, and contours arranged along a guide curve.
- Tool orientation — an explicit step, rather than something the slicer decides for you.
- Path following — dense joint trajectories for printing, milling and welding.
- Travel planning — collision-free moves between poses.
- Collision checking — self and environment, on a single pose, a batch, or a whole trajectory, behind one valid/invalid gate.
- Part placement — searches for a placement where every toolpath frame is both reachable and collision-free.
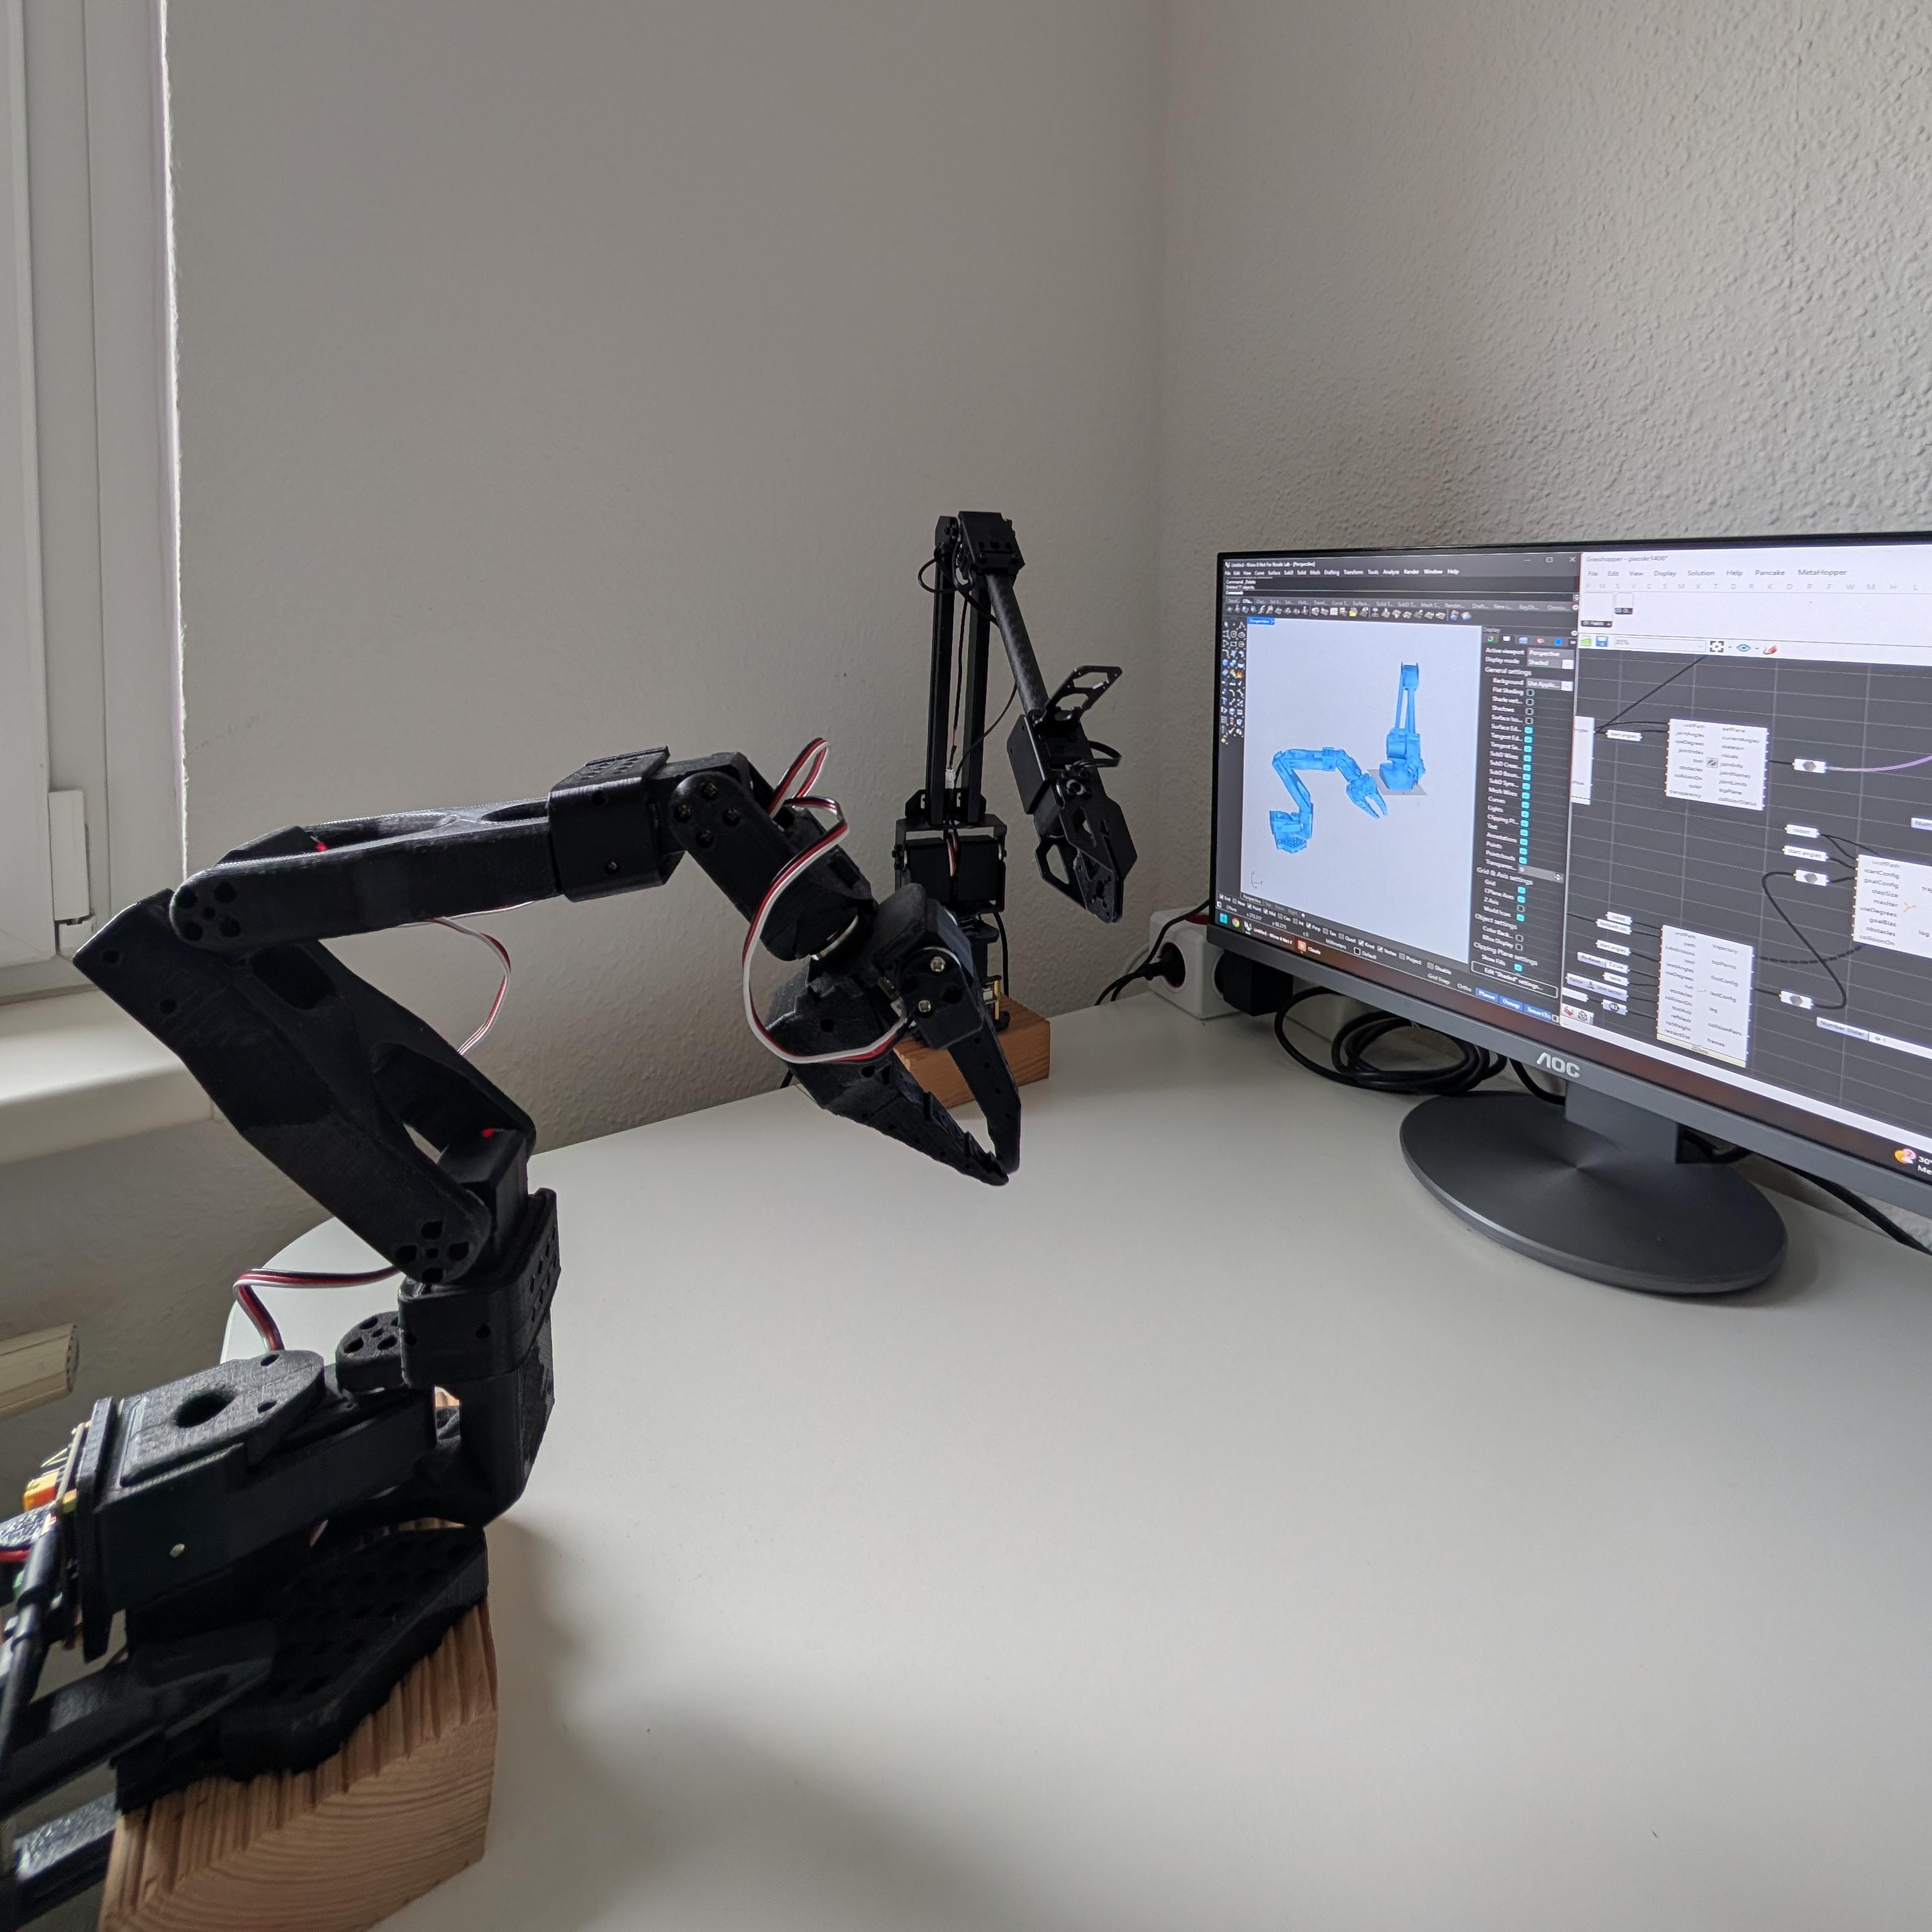
- Serial control — streams to Feetech/ESP32 arms, reads the joints back, and calibrates a mapping against your own unit.
- Fabrication — waffle structures and sheet nesting (e.g. for jigs and fixtures).
Free to download for Rhino 7 (Windows) and Rhino 8 (Windows and macOS).
Developed and maintained at Pixolid UG in Berlin.